2D Observer Form [A(v),B(v),C(v),F(v),H(v)]
R2026bImplement gain-scheduled state-space controller in observer form depending on two scheduling parameters
2D Observer Form [A(v),B(v),C(v),F(v),H(v)] block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Aerospace Blockset /
GNC /
Control
Description
The 2D Observer Form [A(v),B(v),C(v),F(v),H(v)] block implements a gain-scheduled state-space controller as defined in Algorithms.
The output from this block is the actuator demand, which you can input to an actuator block. Use this block to implement a controller designed using H-infinity loop-shaping, one of the design methods supported by Robust Control Toolbox.
Examples
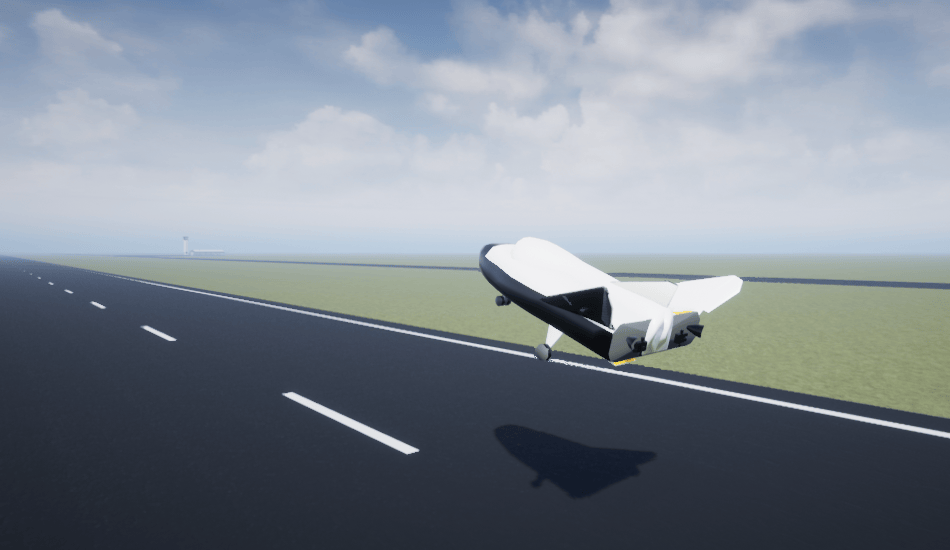
HL-20 with Flight Instrument Blocks and Visualization Using Unreal Engine
Model NASA HL-20 lifting body and controller modeled in Simulink® and Aerospace Blockset™, using Unreal Engine® for visualization.
Limitations
If the scheduling parameter inputs to the block go out of range, they are clipped. The state-space matrices are not interpolated out of range.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"aerolibschedule/2D Observer Form [A(v),B(v),C(v),F(v),H(v)]"
Example: add_block("aerolibschedule/2D Observer Form [A(v),B(v),C(v),F(v),H(v)]","myModel/myBlock",MakeNameUnique="on")
Algorithms
The block implements a gain-scheduled state-space controller defined in the following observer form:
References
[1] Hyde, R. A.. "H-infinity Aerospace Control Design — A VSTOL Flight Application." Advances in Industrial Control Series, Springer Verlag, 1995.
Extended Capabilities
Version History
Introduced before R2006a

