Orbit Follower
R2026bOrbit location of interest using UAV
Orbit Follower block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
UAV Toolbox /
Algorithms
Description
The Orbit Follower block generates course and yaw controls for following a circular orbit around a location of interest based on the current pose of the unmanned aerial vehicle (UAV). Select a UAV type of fixed-wing or multirotor UAVs. You can specify any orbit center location, orbit radius, and turn direction. A lookahead distance, LookaheadDistance, is used for tuning the path tracking and generating the LookaheadPoint output.
Examples
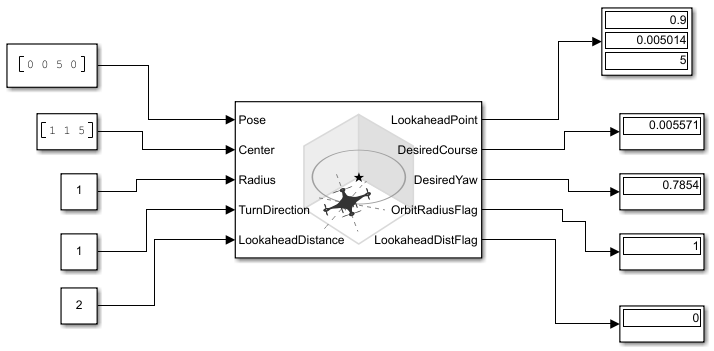
Generate Course and Yaw Commands for Orbit Following in Simulink
Use the UAV Orbit Follower block to generate course and yaw commands for orbiting a location of interest with a UAV.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"uavalgslib/Orbit Follower"
Example: add_block("uavalgslib/Orbit Follower","myModel/myBlock",MakeNameUnique="on")
Extended Capabilities
Version History
Introduced in R2019a

