plot
R2026bDescription
Add-On Required: This feature requires the Automated Driving Toolbox Test Suite for Euro NCAP Protocols add-on.
plot( plots the first frame of the
scenario simulation from the input scenario descriptor object
descriptor)descriptor.
scenarioDescriptorPlotObj = plot(descriptor)ScenarioDescriptorPlot object, scenarioDescriptorPlotObj,
that contains the data to plot and the simulate scenario from the input scenario descriptor
object descriptor.
Examples
Load a driving scenario into the workspace.
load("scenarioWithSingleActor.mat")Create a scenario descriptor from the loaded driving scenario.
scenarioDescriptor = getScenarioDescriptor(sc);
Plot the first frame of the scenario simulation from the scenario descriptor object.
plot(scenarioDescriptor)
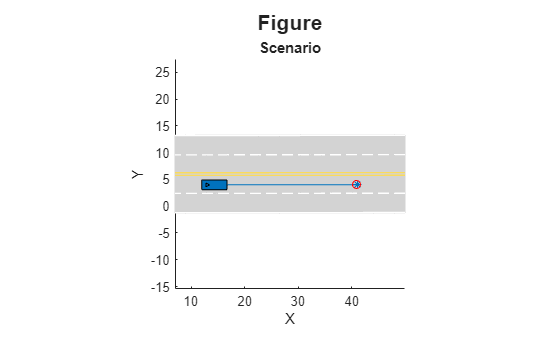
Create a scenario descriptor plot object from the scenario descriptor object.
scenarioDescriptorPlotObj = plot(scenarioDescriptor)
scenarioDescriptorPlotObj =
  ScenarioDescriptorPlot with properties:

       SimulationTime: 0
    MaxSimulationTime: 0.9300

       NumDescriptors: 1
        FigureHandles: [1×1 Figure]

            Waypoints: "StartEnd"
             CropType: "None"
               XLimit: []
               YLimit: []
               ZLimit: []
                Title: "Figure"
        SubPlotTitles: "Scenario"
             GridSize: []
Configure the scenario descriptor plot object to change the title.
configure(scenarioDescriptorPlotObj,Title="Straight Road")Play the entire scenario simulation, instead of displaying only the first frame of the scenario.
play(scenarioDescriptorPlotObj)
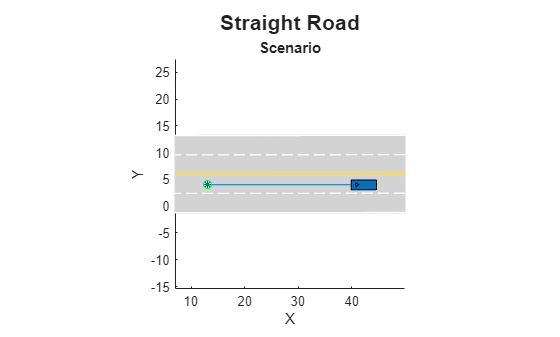
Close the scenario descriptor plot.
close(scenarioDescriptorPlotObj)
Load a MAT file containing two scenario descriptors.
load("scenarioDescriptors")Plot the first frames of the scenario simulations for both loaded scenario descriptors in a single figure.
scenarioDescriptorPlotObj = plot(scenarioDescriptors)
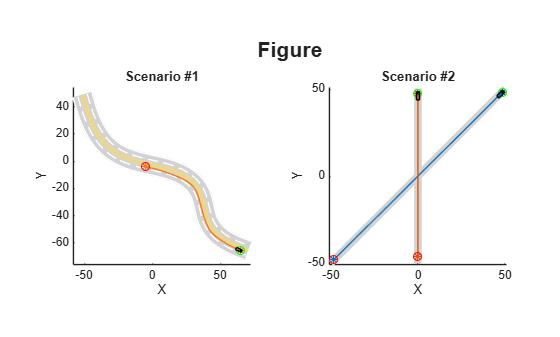
scenarioDescriptorPlotObj =
  ScenarioDescriptorPlot with properties:

       SimulationTime: [2×1 double]
    MaxSimulationTime: [2×1 double]

       NumDescriptors: 2
        FigureHandles: [1×1 Figure]

            Waypoints: "StartEnd"
             CropType: "None"
               XLimit: []
               YLimit: []
               ZLimit: []
                Title: "Figure"
        SubPlotTitles: ["Scenario #1"    "Scenario #2"]
             GridSize: []
Configure the scenario descriptor plot object to change the title and subplot titles.
configure(scenarioDescriptorPlotObj,Title="Scenarios",SubPlotTitles=["Curved Road" "Straight Road"])
Play the entirety of both scenario simulations, instead of displaying only the first frame of each.
play(scenarioDescriptorPlotObj)
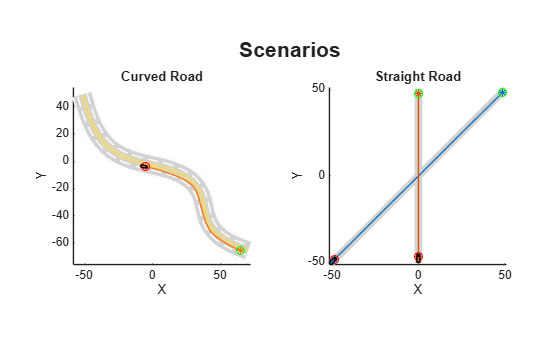
Close the scenario descriptor plot.
close(scenarioDescriptorPlotObj)
Input Arguments
Output Arguments
Limitations
The
plot,play, andseekfunctions display the lane markings at a junction if that junction has been created without using theroadGroupfunction.The
plot,play, andseekfunctions do not support Composite Lane Marking and lanes created using thecompositeLaneSpecobject.
Version History
Introduced in R2026a
See Also
ScenarioDescriptorPlot | configure | play | seek | close | getScenarioDescriptor | getScenario | drivingScenario

