Speed Measurement
R2026bCompute speed from rotor angular position
Speed Measurement block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Motor Control Blockset /
Control /
Induction Machine /
Position Decoders /
Sensor Decoders
Motor Control Blockset /
Control /
Synchronous Machine /
Position Decoders /
Sensor Decoders
Motor Control Blockset HDL Support /
Sensor Decoders
Description
The Speed Measurement block calculates the angular speed from the angular position of the rotor by calculating the change in the angular position with respect to time.
Examples
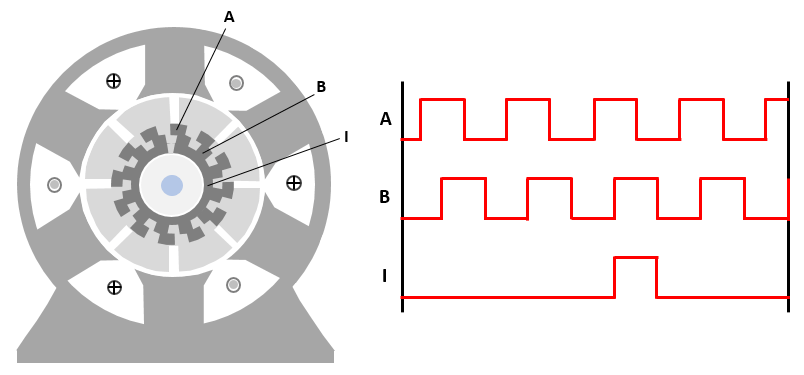
Field-Oriented Control of Induction Motor Using Speed Sensor
Implements the field-oriented control (FOC) technique to control the speed of a three-phase AC induction motor (ACIM). The FOC algorithm requires rotor speed feedback, which is obtained in this example by using a quadrature encoder sensor. For details about FOC, see Field-Oriented Control.
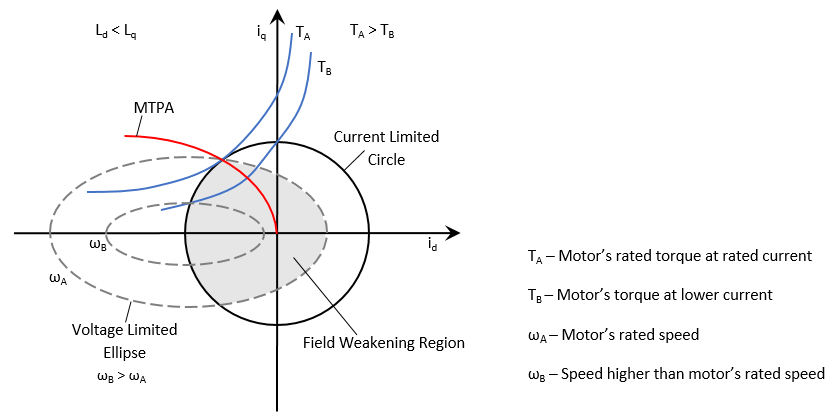
Field-Weakening Control (with MTPA) of PMSM
Implements the field-oriented control (FOC) technique to control the torque and speed of a three-phase permanent magnet synchronous motor (PMSM). The FOC algorithm requires rotor position feedback, which is obtained by a quadrature encoder sensor. For details about FOC, see Field-Oriented Control.
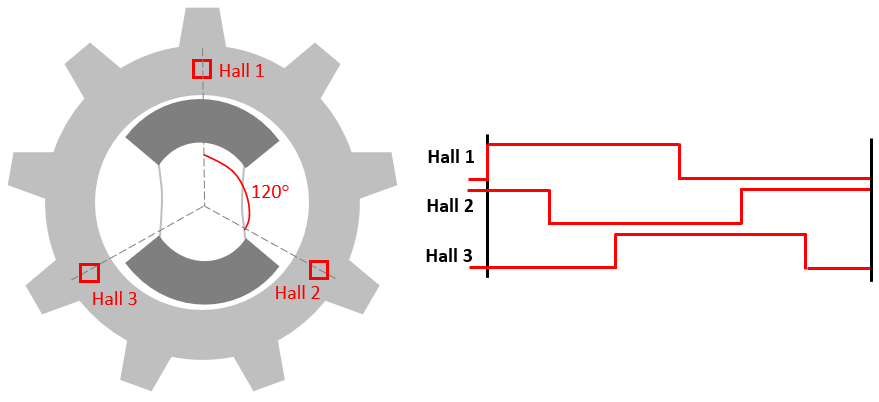
Field-Oriented Control of PMSM Using Hall Sensor
Implements the field-oriented control (FOC) technique to control the speed of a three-phase permanent magnet synchronous motor (PMSM). The FOC algorithm requires rotor position feedback, which is obtained by a Hall sensor. For details about FOC, see Field-Oriented Control.
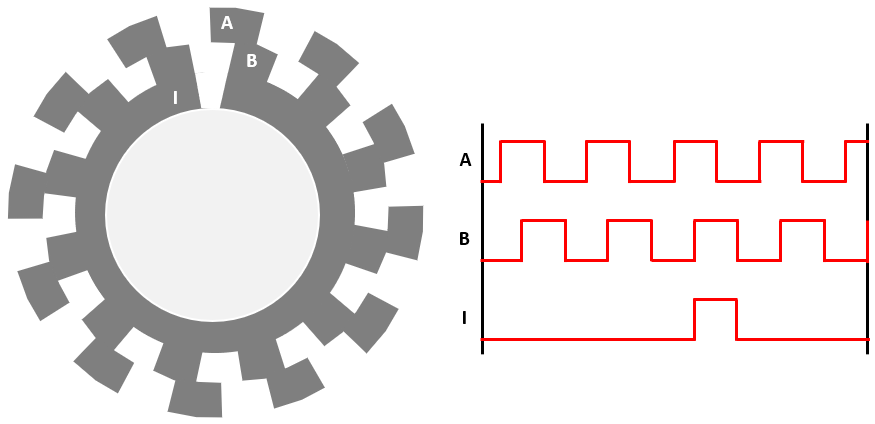
Field-Oriented Control of PMSM Using Quadrature Encoder
Implements the field-oriented control (FOC) technique to control the speed of a three-phase permanent magnet synchronous motor (PMSM). The FOC algorithm requires rotor position feedback, which is obtained by a quadrature encoder sensor. For details about FOC, see Field-Oriented Control.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"mcblib/Control/Induction Machine/Position Decoders/Sensor Decoders/Speed Measurement"
"mcblib/Control/Synchronous Machine/Position Decoders/Sensor Decoders/Speed Measurement"
"mcbhdllib/Sensor Decoders/Speed Measurement"
Example: add_block("mcblib/Control/Induction Machine/Position Decoders/Sensor Decoders/Speed Measurement","myModel/myBlock",MakeNameUnique="on")

