SoRoSim
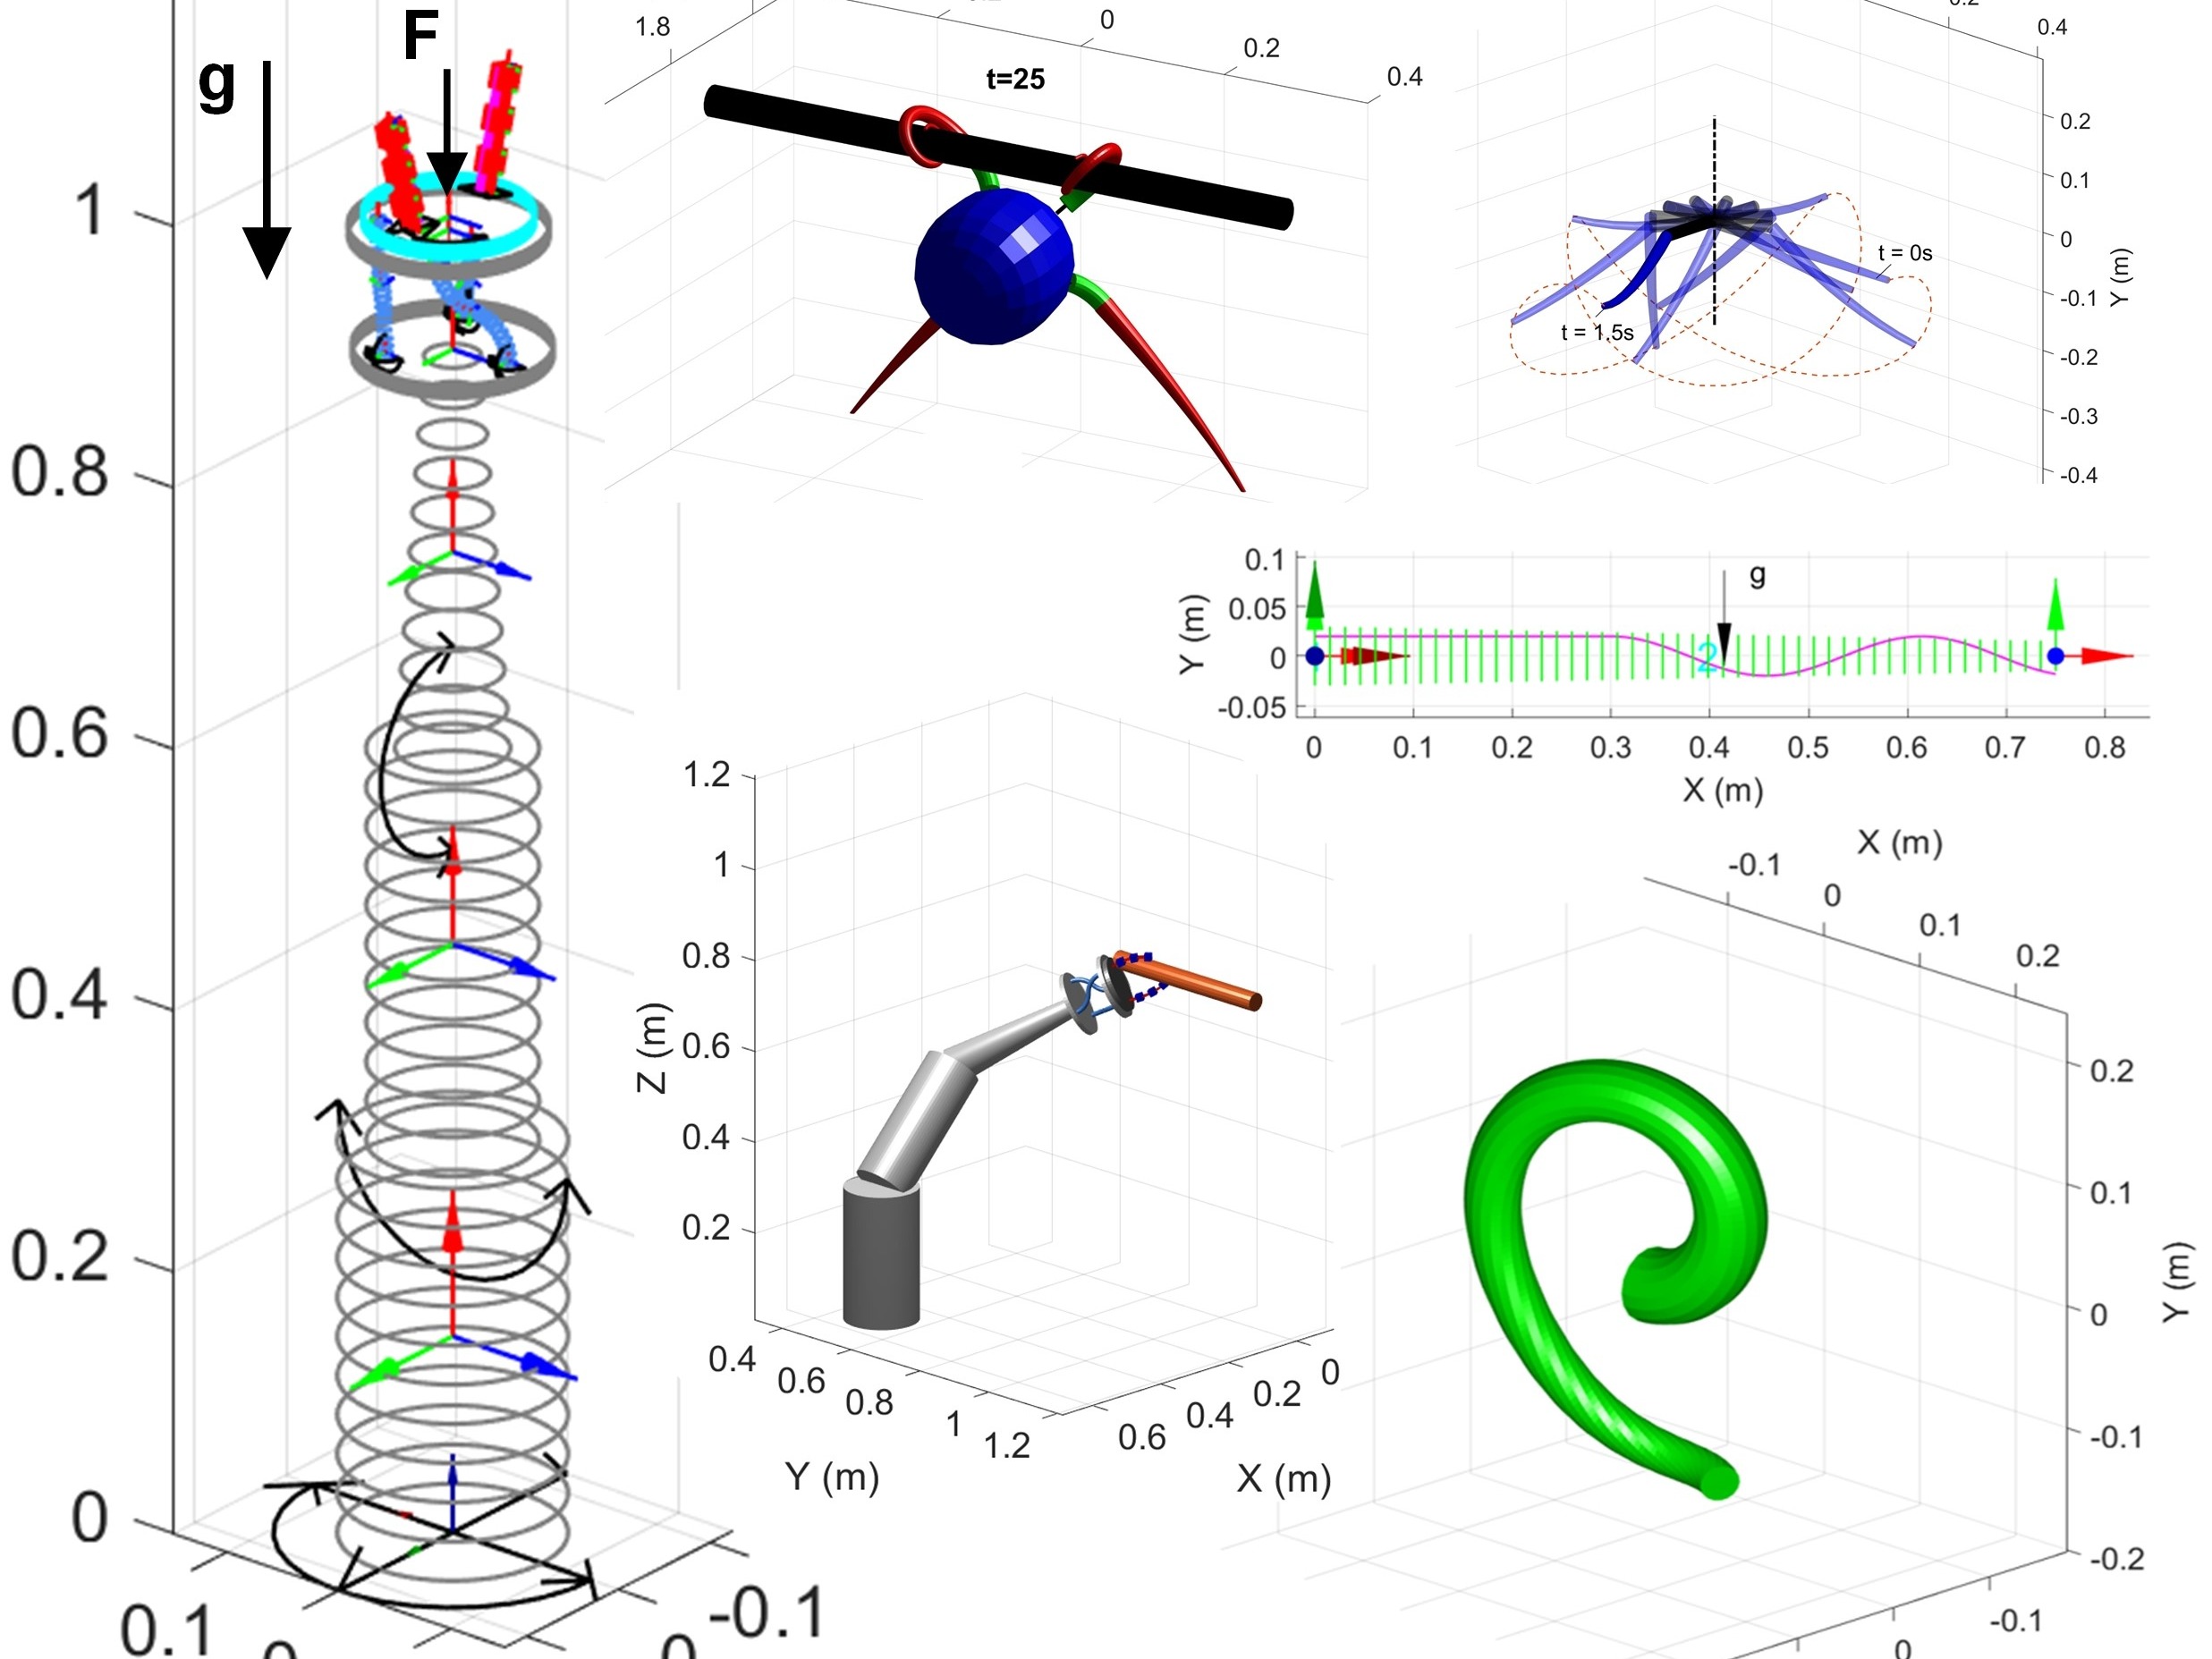
A unified simulation and analysis platform for soft, rigid and hybrid robotic systems.

Vous suivez désormais cette soumission
- Les mises à jour seront visibles dans votre flux de contenu suivi
- Selon vos préférences en matière de communication il est possible que vous receviez des e-mails
Citation pour cette source
@ARTICLE{9895355, author={Mathew, Anup Teejo and Hmida, Ikhlas Ben and Armanini, Costanza and Boyer, Frederic and Renda, Federico}, journal={IEEE Robotics & Automation Magazine}, title={SoRoSim: A MATLAB Toolbox for Hybrid Rigid–Soft Robots Based on the Geometric Variable-Strain Approach}, year={2023}, volume={30}, number={3}, pages={106-122}, keywords={Robots;Mathematical models;Strain;Soft robotics;Robot kinematics;Matlab;Analytical models}, doi={10.1109/MRA.2022.3202488}}
@article{mathew2025reduced, title={Reduced order modeling of hybrid soft-rigid robots using global, local, and state-dependent strain parameterization}, author={Mathew, Anup Teejo and Feliu-Talegon, Daniel and Alkayas, Abdulaziz Y and Boyer, Frederic and Renda, Federico}, journal={The International Journal of Robotics Research}, volume={44}, number={1}, pages={129--154}, year={2025}, publisher={SAGE Publications Sage UK: London, England} }
Informations générales
- Version (15,6 Mo)
Compatibilité avec les versions de MATLAB
- Compatible avec toutes les versions
Plateformes compatibles
- Windows
- macOS
- Linux
| Version | Publié le | Notes de version | Action |
|---|---|---|---|
| 7.0.0 | - Algorithms now use analytical derivatives of the governing equations.
|
||
| 6.3.0 | - Version number |
||
| 4.0.0 | - Users can choose basis functions for strain computation
|
||
| 3.3.1 | - Added sources to toolbox description |
||
| 3.3.0 | - Files added to Basic functions folder to optimize processing speed |
||
| 3.2.0 | - Faster dynamic simulation
|
||
| 3.1.0 | - MATLAB Live Script files added for easier example demonstration
|
||
| 3.0.1 | - Folder Organization |
||
| 3.0.0 | - SoRoSim can now model closed-chain and branched robotic structures
|
||
| 2.32.0 | - Solving improvements to optimize simulation time
|
||
| 2.31.0 | - Adjustments to normalizing Linkages |
||
| 2.3.0 | - Improved user interface |
||
| 2.2.0 | Updated Examples |
||
| 2.1.0 | - Computations of soft links are done after normalization for faster and more stable simulations.
|
||
| 2.0.0 | - Toolbox can now handle variable strain problems.
|
||
| 1.0.0 |

